Industrial project, Master's capstone, RMIT, 2024 to 2025
Motorised warp beam system for an automated trampoline manufacturing machine
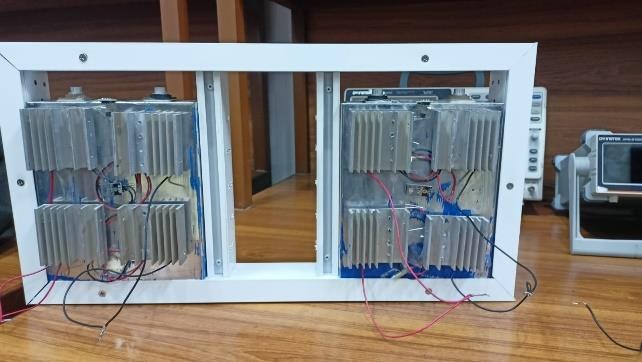
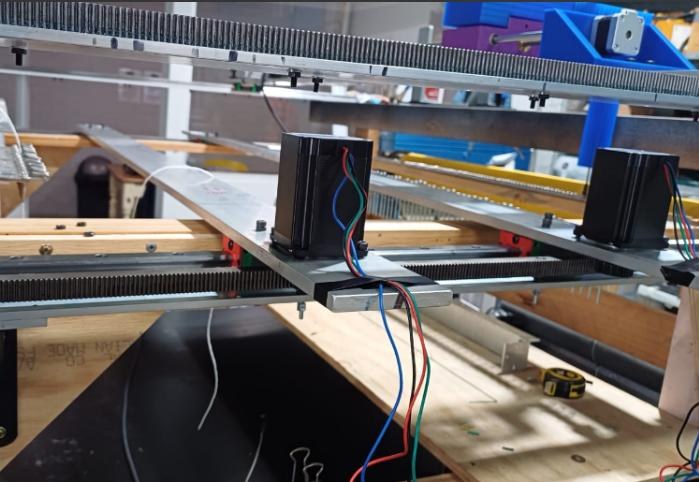
Mr Trampoline's weaving machines still need an operator to hook and tension every warp yarn. With RMIT, the company is building a fully automated prototype, and my research covered its warp beams. An earlier moving-beam design had failed because the gear and rack were modelled badly, so I fixed the CAD, fabricated rack and pinion beam drives with stepper motors, and tested them. This phase delivered the mechanical base. Closed-loop tension control is the next stage.
What I found. A 2 mm error in rack height caused inconsistent gear mating, and moves that worked in CAD failed on the real frame because of tolerances.
My role. I ran the FMEA, redesigned the beams in CAD, fabricated and tested the beam drive, and chose the rack and pinion design. I assisted with the strain gauge calibration, the wiring and the Arduino code.
SolidWorks
Arduino
Stepper motors
Rack and pinion
FMEA
How the project unfolded
Semester 1
Attempt
Calibrated three strain gauges and tested tension with the roller motor.
Semester 1
Diagnose
The beams could not move, because the earlier gear and rack design jammed.
Semester 2
Redesign
Fixed the CAD and built rack and pinion beam drives with stepper motors.
Semester 2
Validate
Tested beam movement and repeatability on the real prototype.
Next Strain gauges on the moving beam, closed-loop tension control and integration with the XY robot.
Open project page